
Note
Go to the end to download the full example code.
Lyapunov’s direct method#
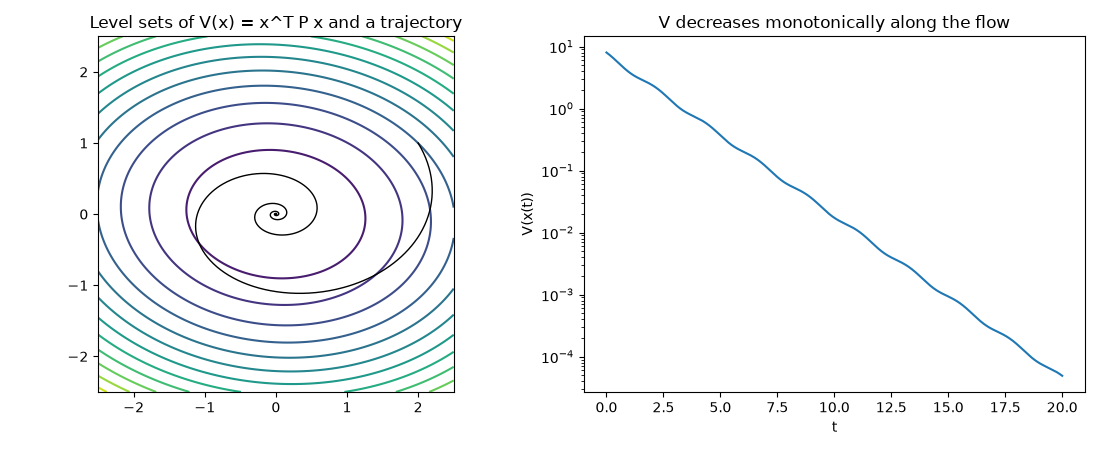
For a stable linear system \(\dot x = Ax\), solving the Lyapunov equation \(A^T P + PA = -Q\) gives an energy-like function \(V(x) = x^T P x\) whose level sets are ellipses that every trajectory crosses inward – a proof of stability that never solves the ODE itself.
import matplotlib.pyplot as plt
import numpy as np

from mathematicskit.ode_dynamics.systems.phase_portrait import Linear2D
from mathematicskit.ode_dynamics.systems.stability import lyapunov_quadratic_form

A = np.array([[-0.3, 2.0], [-1.0, -0.3]])
res = lyapunov_quadratic_form(A)
print("P =\n", np.round(res.P, 4))
print("P positive definite (origin asymptotically stable):", res.positive_definite)
P =
 [[1.2679 0.1196]
 [0.1196 2.4641]]
P positive definite (origin asymptotically stable): True
Trajectories cross the level sets of V inward#
xs = np.linspace(-2.5, 2.5, 200)
X, Y = np.meshgrid(xs, xs)
V = res.P[0, 0] * X**2 + 2 * res.P[0, 1] * X * Y + res.P[1, 1] * Y**2
traj = Linear2D([2.0, 1.0], A=A).integrate((0.0, 20.0), dt=1e-2, method="rk4")
V_traj = np.einsum("ti,ij,tj->t", traj.y, res.P, traj.y)

fig, axes = plt.subplots(1, 2, figsize=(11, 4.5))
axes[0].contour(X, Y, V, levels=12, cmap="viridis")
axes[0].plot(traj.y[:, 0], traj.y[:, 1], "k", lw=1)
axes[0].set_aspect("equal")
axes[0].set_title("Level sets of V(x) = x^T P x and a trajectory")
axes[1].semilogy(traj.t, V_traj)
axes[1].set_xlabel("t")
axes[1].set_ylabel("V(x(t))")
axes[1].set_title("V decreases monotonically along the flow")
fig.tight_layout()
An unstable matrix admits no positive-definite P#
print("unstable spiral, P positive definite:", lyapunov_quadratic_form([[0.1, 1.0], [-1.0, 0.1]]).positive_definite)

plt.show()
unstable spiral, P positive definite: False
Total running time of the script: (0 minutes 0.330 seconds)