
Note
Go to the end to download the full example code or to run this example in your browser via JupyterLite.
Luenberger’s observer (1964)#
State feedback needs every state, but sensors measure only some of them.
David Luenberger (1964) built the missing states from a copy of the model
driven by the same input and corrected by the output error,
\(\dot{\hat x} = A\hat x + Bu + L(y - C\hat x)\). The estimation error
\(e = x - \hat x\) then obeys \(\dot e = (A - LC)e\) whatever the
input, and if \((A, C)\) is observable the gain \(L\) places those
error poles anywhere (observer_gain()).
A lightly damped mass on a spring is measured by its position only; the observer recovers the velocity.
import matplotlib.pyplot as plt
import numpy as np
from scipy import linalg
from scipy.integrate import solve_ivp

from engineeringkit.control_systems import is_observable, observer_gain

A = np.array([[0.0, 1.0], [-4.0, -0.2]])  # natural frequency 2 rad/s, damping ratio 0.05
B = np.array([[0.0], [1.0]])
C = np.array([[1.0, 0.0]])
assert is_observable(A, C)
error_poles = [-3.0, -4.0]
L = observer_gain(A, C, error_poles)
print("observer gain L =", L.ravel().round(4).tolist())
assert np.allclose(np.sort(np.linalg.eigvals(A - L @ C).real), [-4, -3])


def u(t):
    return np.sin(1.3 * t)


def rhs(t, z):
    x, xhat = z[:2], z[2:]
    y = C @ x
    return np.concatenate((A @ x + B[:, 0] * u(t), A @ xhat + B[:, 0] * u(t) + L @ (y - C @ xhat)))


x0, xhat0 = np.array([1.0, 0.5]), np.zeros(2)
t = np.linspace(0, 6, 601)
sol = solve_ivp(rhs, (0, 6), np.concatenate((x0, xhat0)), t_eval=t, rtol=1e-10, atol=1e-12)
x, xhat = sol.y[:2], sol.y[2:]
observer gain L = [6.8, 6.64]
The error follows the placed poles exactly#
predicted = np.array([linalg.expm((A - L @ C) * tk) @ (x0 - xhat0) for tk in t]).T
assert np.allclose(x - xhat, predicted, atol=1e-7)
# Velocity error falls by e^-3 per second or faster once the transient settles.
print(f"velocity error at t = 0, 2, 4 s: {np.abs(x[1] - xhat[1])[[0, 200, 400]].round(5).tolist()}")
assert np.abs(x[1] - xhat[1])[400] < 1e-4

fig, (ax1, ax2) = plt.subplots(2, 1, sharex=True, figsize=(7, 6))
ax1.plot(t, x[0], "k-", label="position (measured)")
ax1.plot(t, xhat[0], "C0--", label="estimate")
ax1.legend()
ax2.plot(t, x[1], "k-", label="velocity (not measured)")
ax2.plot(t, xhat[1], "C0--", label="estimate")
ax2.set(xlabel="time [s]")
ax2.legend()
ax1.set(title=f"Observer error poles {error_poles}")

plt.show()
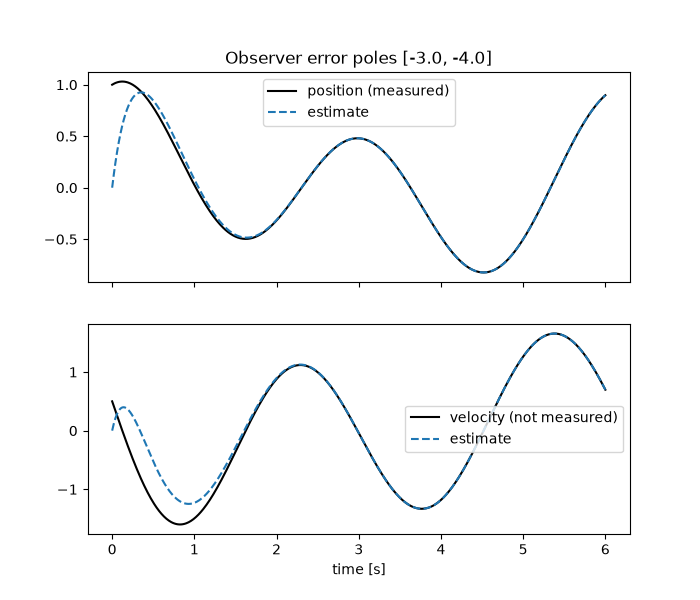
velocity error at t = 0, 2, 4 s: [0.5, 0.01856, 5e-05]
Total running time of the script: (0 minutes 0.053 seconds)
